Synthetic Data for Robotics
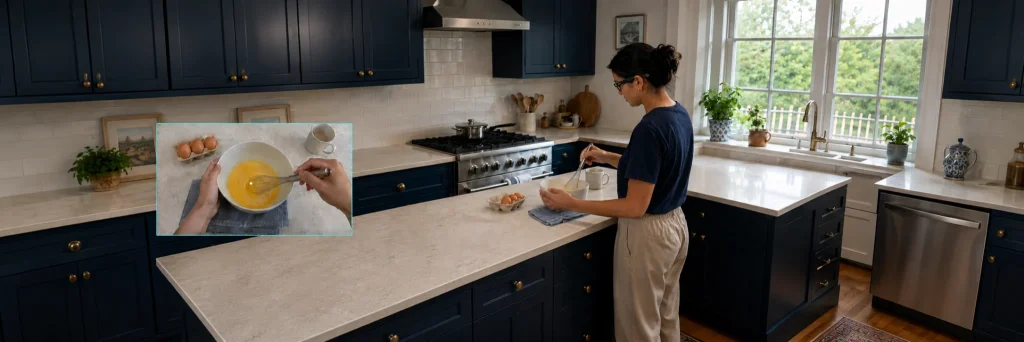
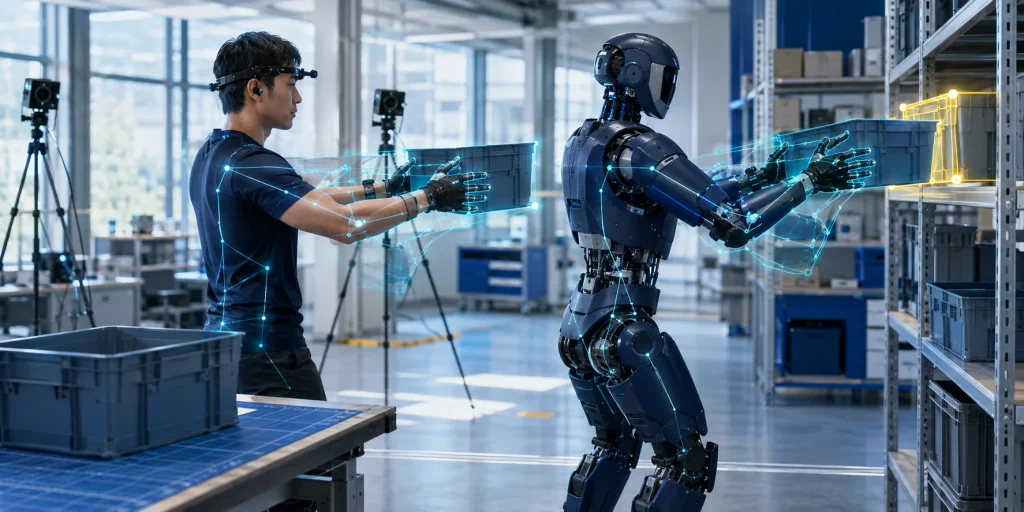
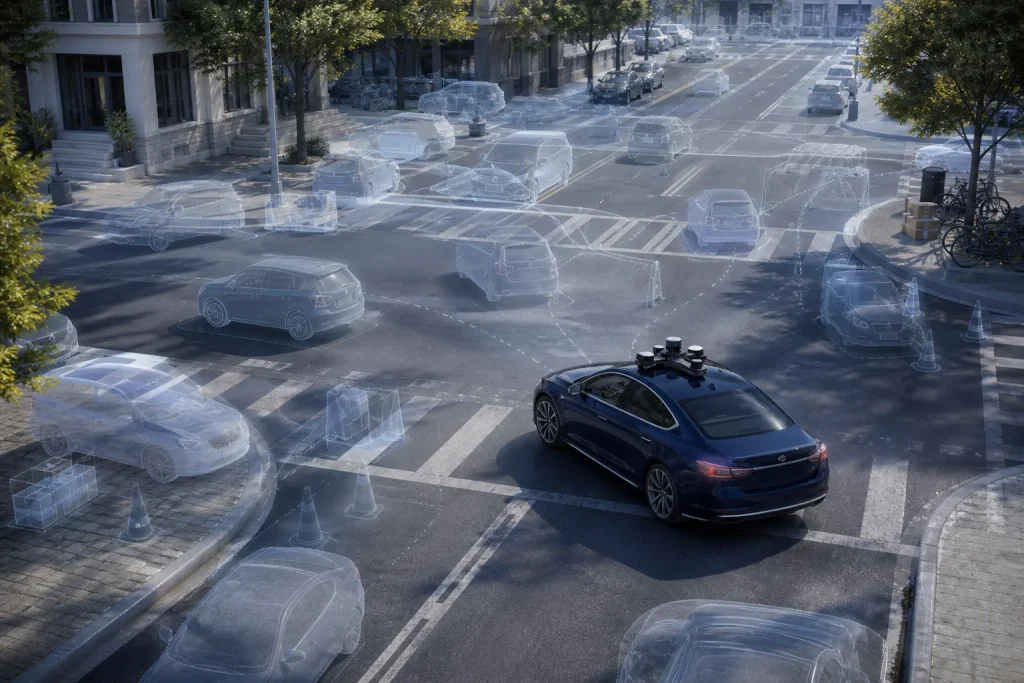
What a generated episode contains once its pixels or its actions come from a model rather than a sensor, why the mixing ratio against real data decides whether co-training helps, and where a corpus stops recording which episodes were measured.
Synthetic Data for Robotics Read More »